
Furuta Pendulum and Triple Pendulum

As a lead of the Nonlinear Control group's robotics team, I recently had the privilege of proposing a project of my own. Since Columbia's control system lecturers didn't have any hardware to test their students' projects, I decided it was prudent to develop a solution for them. Thus, I decided to make a Furuta pendulum after seeing a video by Ben Katz. I brought this idea up to my lab advisor, Professor Homayoon Beigi, who then remarked that I should make the system expandable to 3 links so that it would be relevant for the most advanced control system courses, as well as a useful exercise in dynamic modelling for me.
I also decided to use a BLDC motor, as I have yet to have a project where Field Oriented Control (FOC) was the focus, and this topic intrigues me greatly. Therefore, with the goal in mind, I submitted some orders to my professor and designed a basic housing.
I ended up incorporating a slip ring, a few bearings, an ESP-32, an ODESC, and a BLDC outrunner motor with a KV of around 800, connected via a belt and pulley with a 3:1 reduction ratio to the spinning chamber, which is connected to the pendulum rod. My initial design for this system is below.


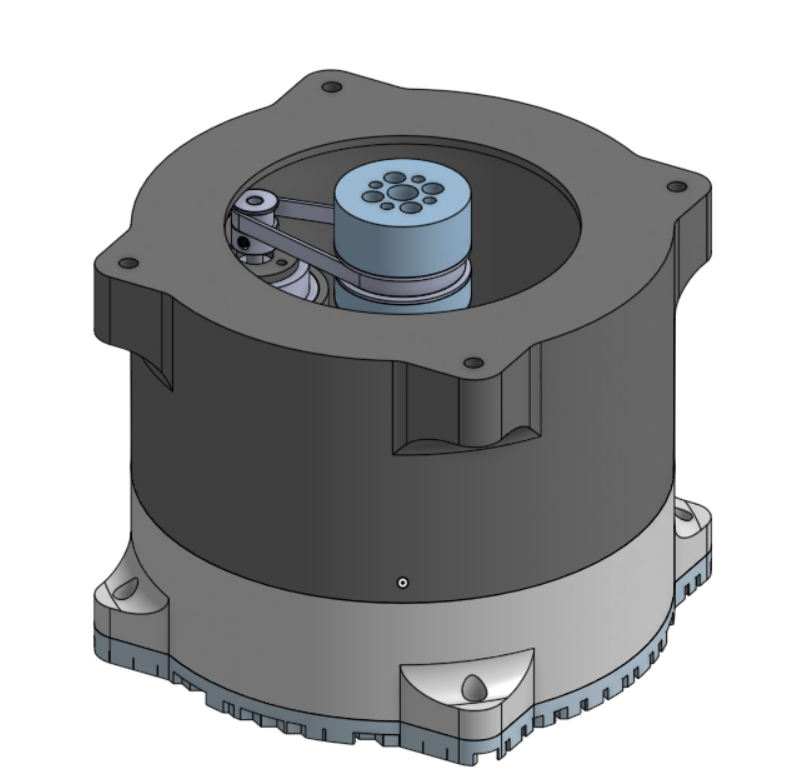

I am also updating this project as I make progress! Check back in a week or two for more updates!


Comments