
Compaction and Sorting Unit for Recyclable Waste

A common problem in waste management is the need to sort waste. There are many ways to do so, ranging from hiring human sorters to cutting-edge AI vision systems that recognize objects and sort them by looking at data. A commonality among these solutions is that they all currently utilize a large-scale sortation plant.
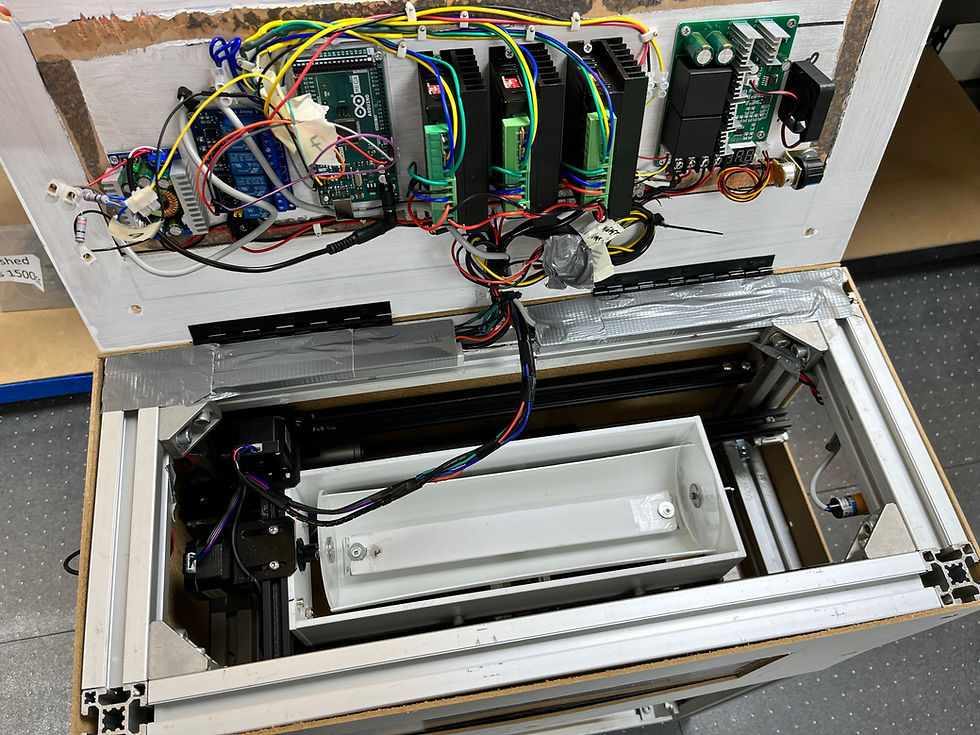
This project seeks to ascertain if it is possible to achieve the same reliable sorting of waste without having to take advantage of scale. It also seeks to compress the waste, if possible, to improve the efficiency of transporting it and allow for a wider range of vehicles to transport it instead of just vehicles equipped with waste compactors. I undertook this project with my grandfather during the summer of my freshman year in college.
In this project, my grandfather and I designed a system that used as little information as possible to determine the type of material being recycled and compressed it to take up as little volume as possible within the waste receptacle. This project consisted of an Arduino Mega, several stepper motors and DC motors, as well as some limit switches and relays. In addition to this, I also used linear actuators, a heating element to soften the plastic bottles to compress them further, and several sensors, such as an inductive sensor and a proximity sensor. The main learning takeaways from this project were understanding sensor data as well as learning how to use microcontrollers and various methods of actuation.


Comments